| I&T Solution |
Palm Tree Climbing Robot
(REF: S-2096) |
| Trial Project |
|
| Solution Feature |
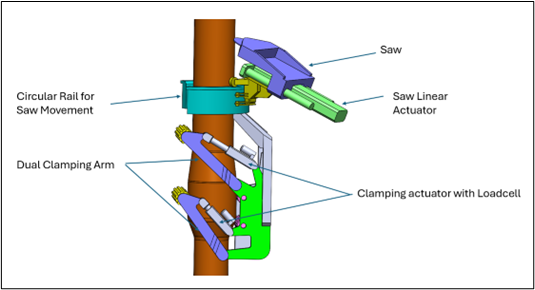
- The Safety dual-clamping system utilizes independent load cells and linear motor actuators to provide continuous force monitoring and redundant mechanical locking, ensuring a fail-safe 'Zero-Drop' operation while automatically adapting to trunk diameter variations.
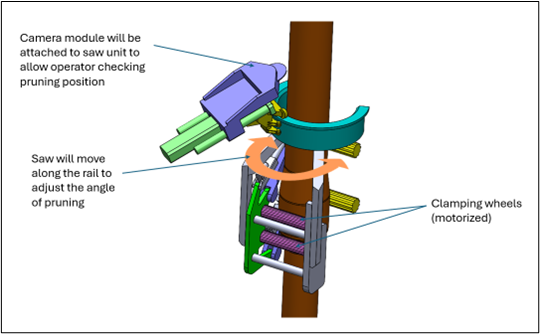
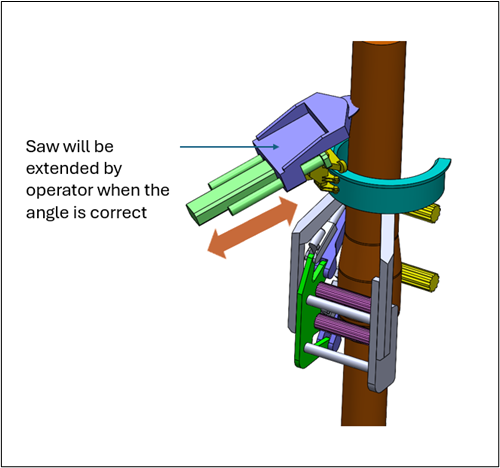
- The intuitive 3-axis interface simplifies complex pruning into three logical maneuvers—vertical climbing, 180° orbital rotation, and precision saw extension—enabling non-technical site staff to execute cuts with minimal training via a live-streamed handheld console.
|
| Trial Application and Expected Outcome |
- Trial involves phased deployment: initially calibrating Active-Grip sensors on unoccupied trunks, followed by supervised pruning of withered fronds at 8-18m. We will log metrics on battery performance, climbing stability, and operator usability to refine the robot's autonomous logic and real-world operational efficiency.
- Testing against varied weather and trunk textures validates our "Zero-Drop" logic and 3-axis UI. This evidence-based feedback cycle ensures the final product is a certified, field-ready asset
|
| Additional Solution Information |
P004 Proposal Palm Tree Climbing.pdf
|
| Info on I&T Solution Provider |
| Solution Provider | : | Quick Rabbit Engineering Company Limited | | Address | : | Unit 1805-06, 18/F, | | Contact Person | : | Johnny Wong |
| Position | : | Engineer | | Tel | : | 84032902 | | Email | : |
johnny.wong@quickrabbiteng.com |
|